
Research / Mobile robotics
Ground
robot.
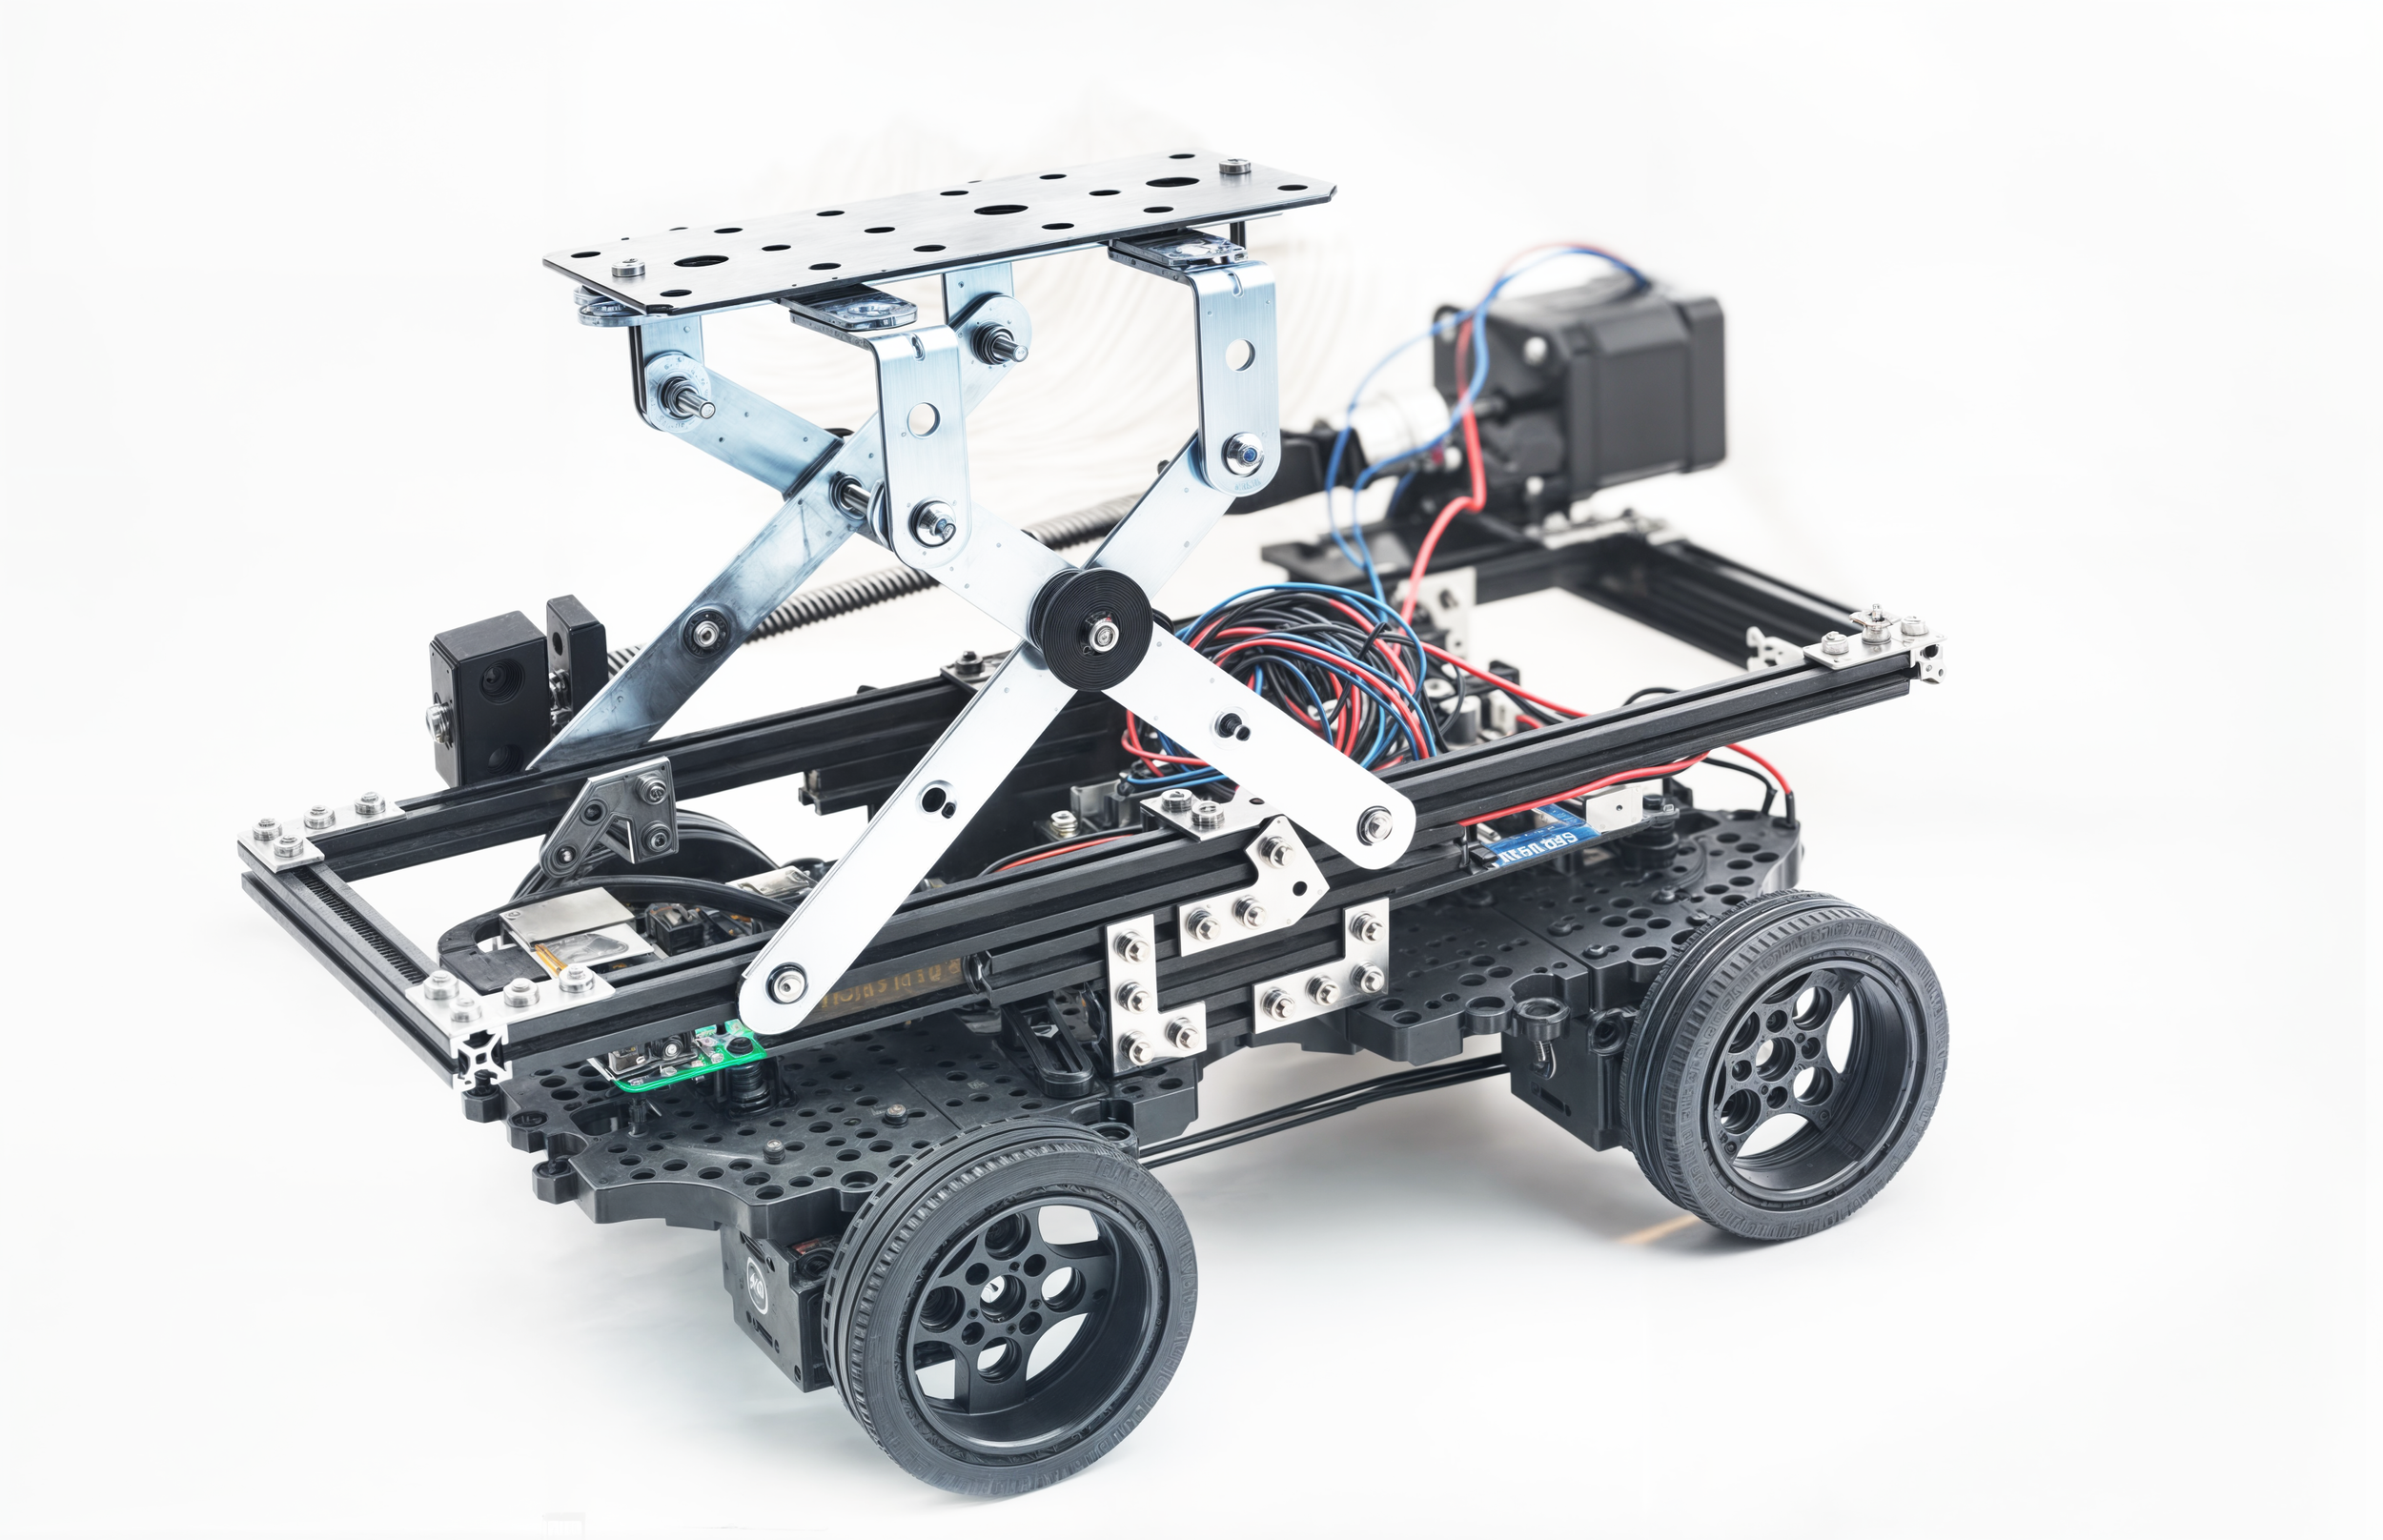
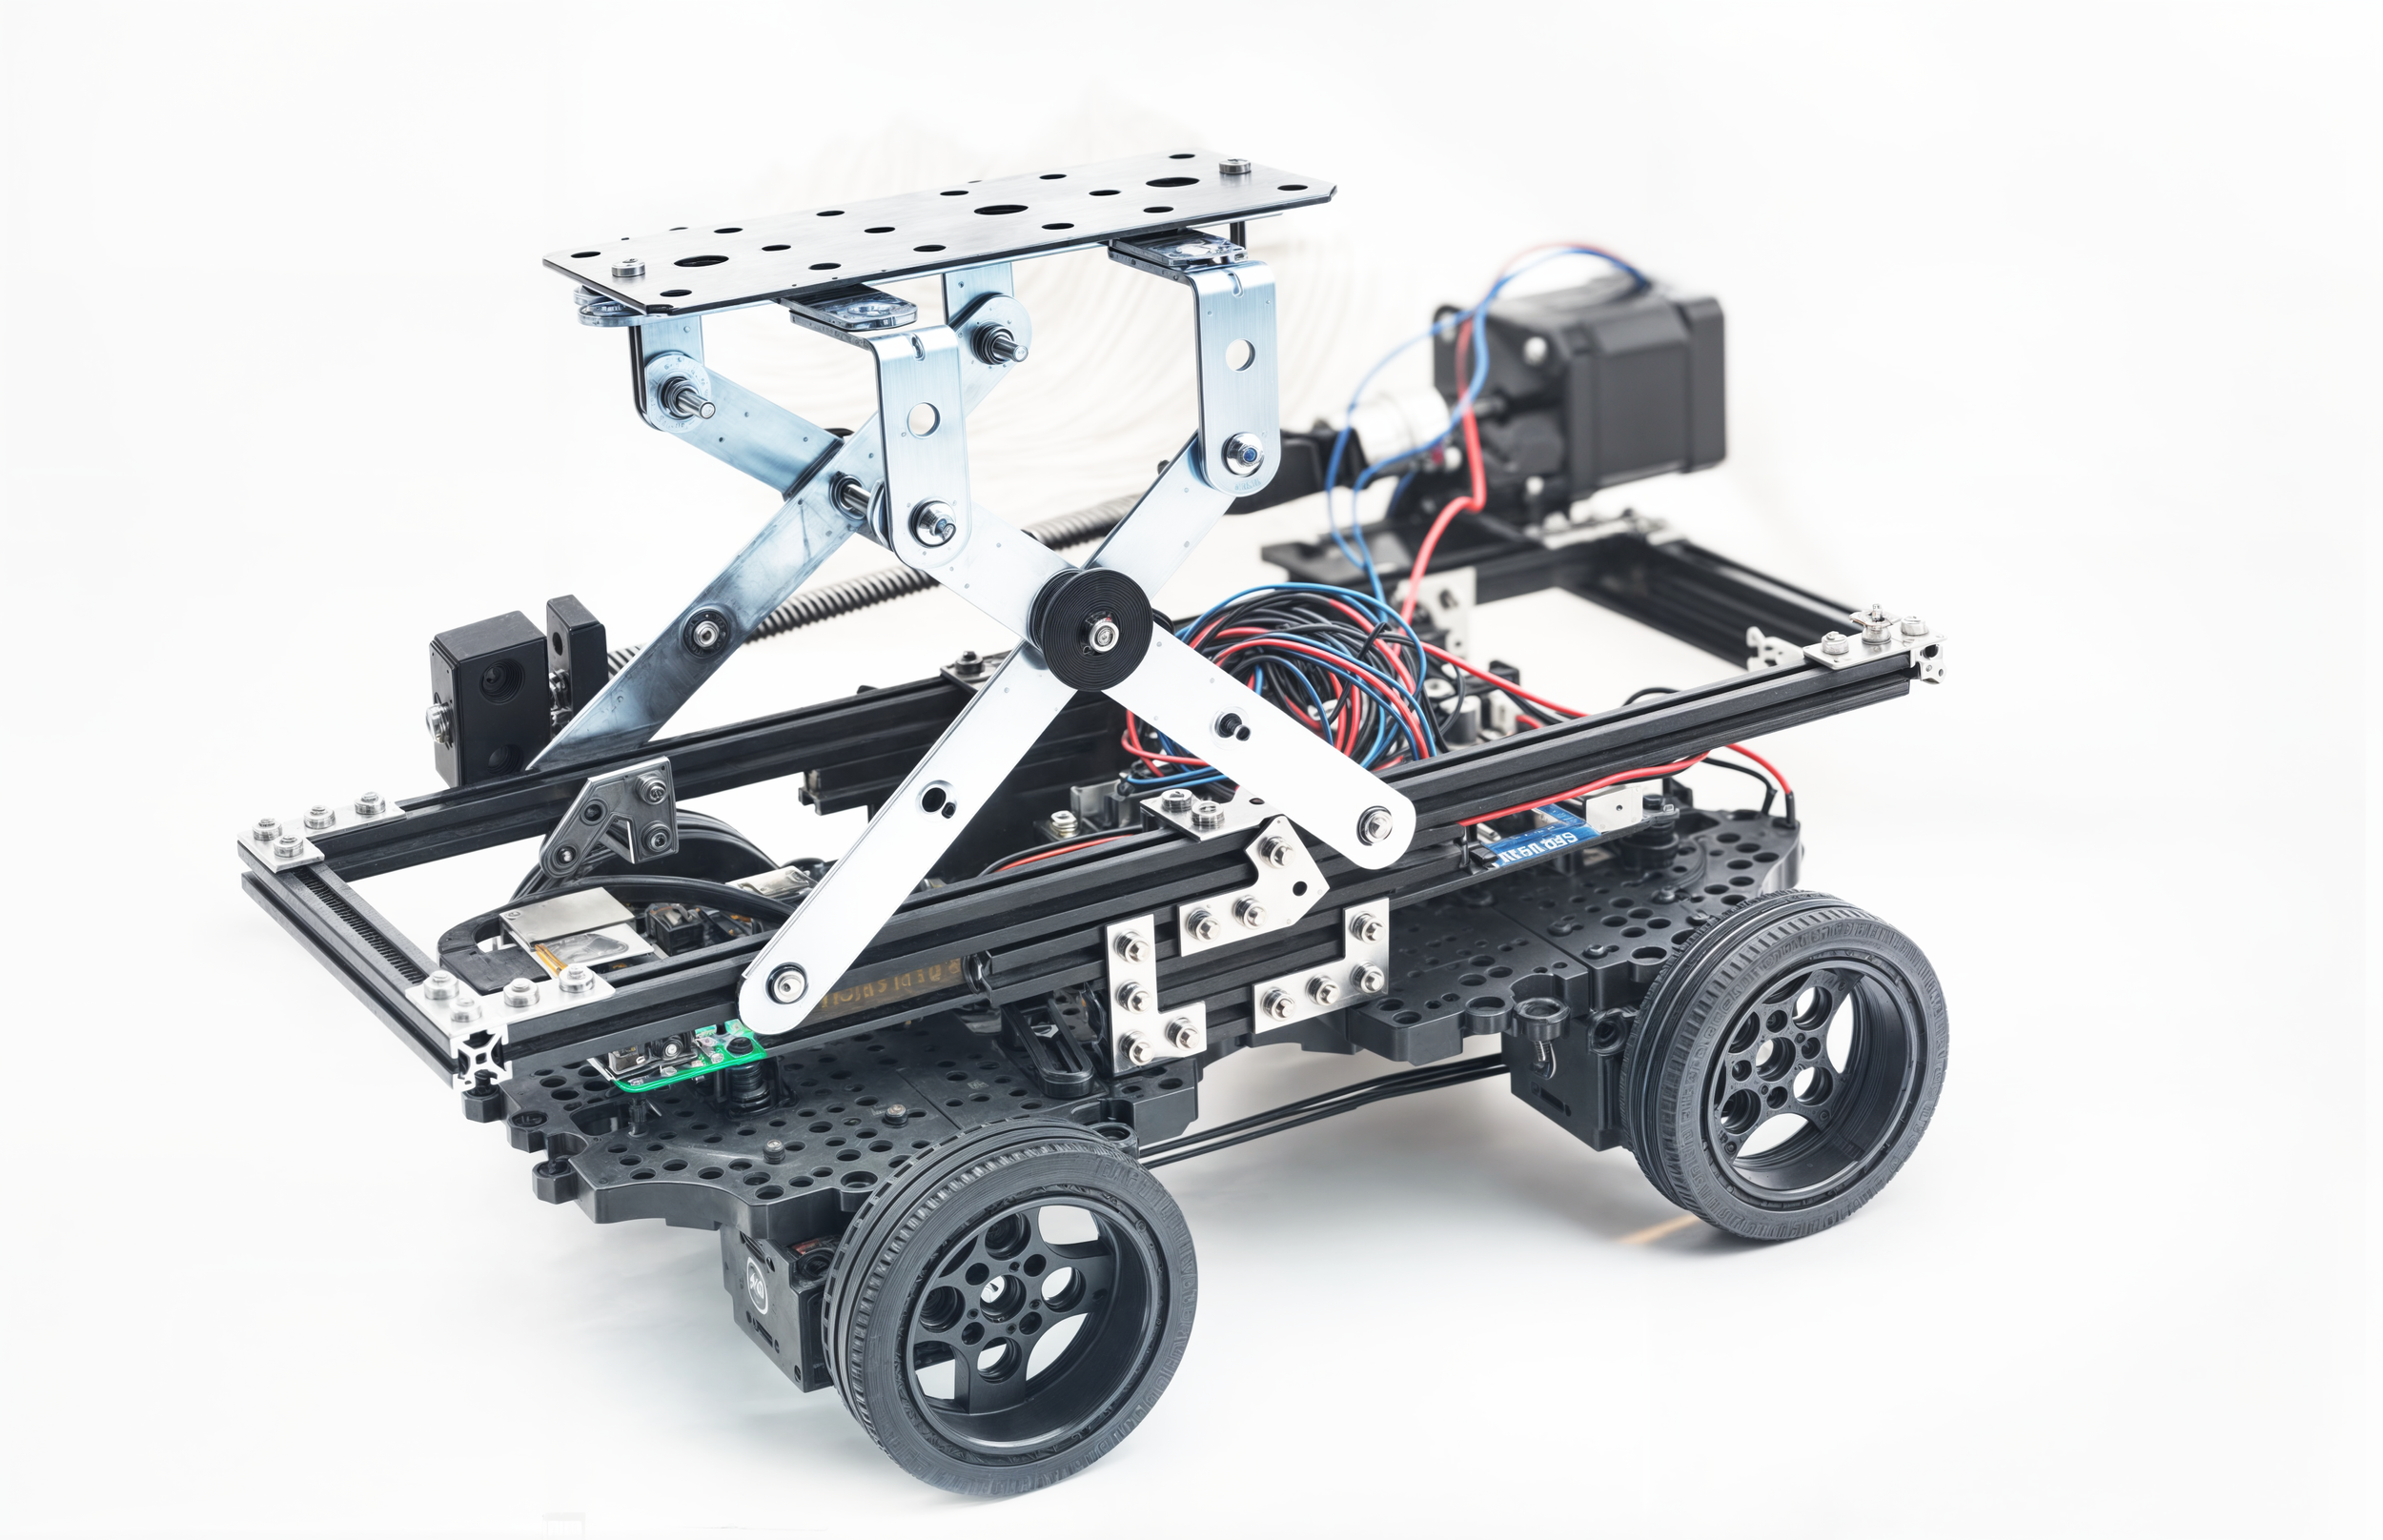
A mobile robotic platform combining ground movement, embedded control and object lifting.
Promytheus / Physical prototype
01 / Platform & control
Mobile base.
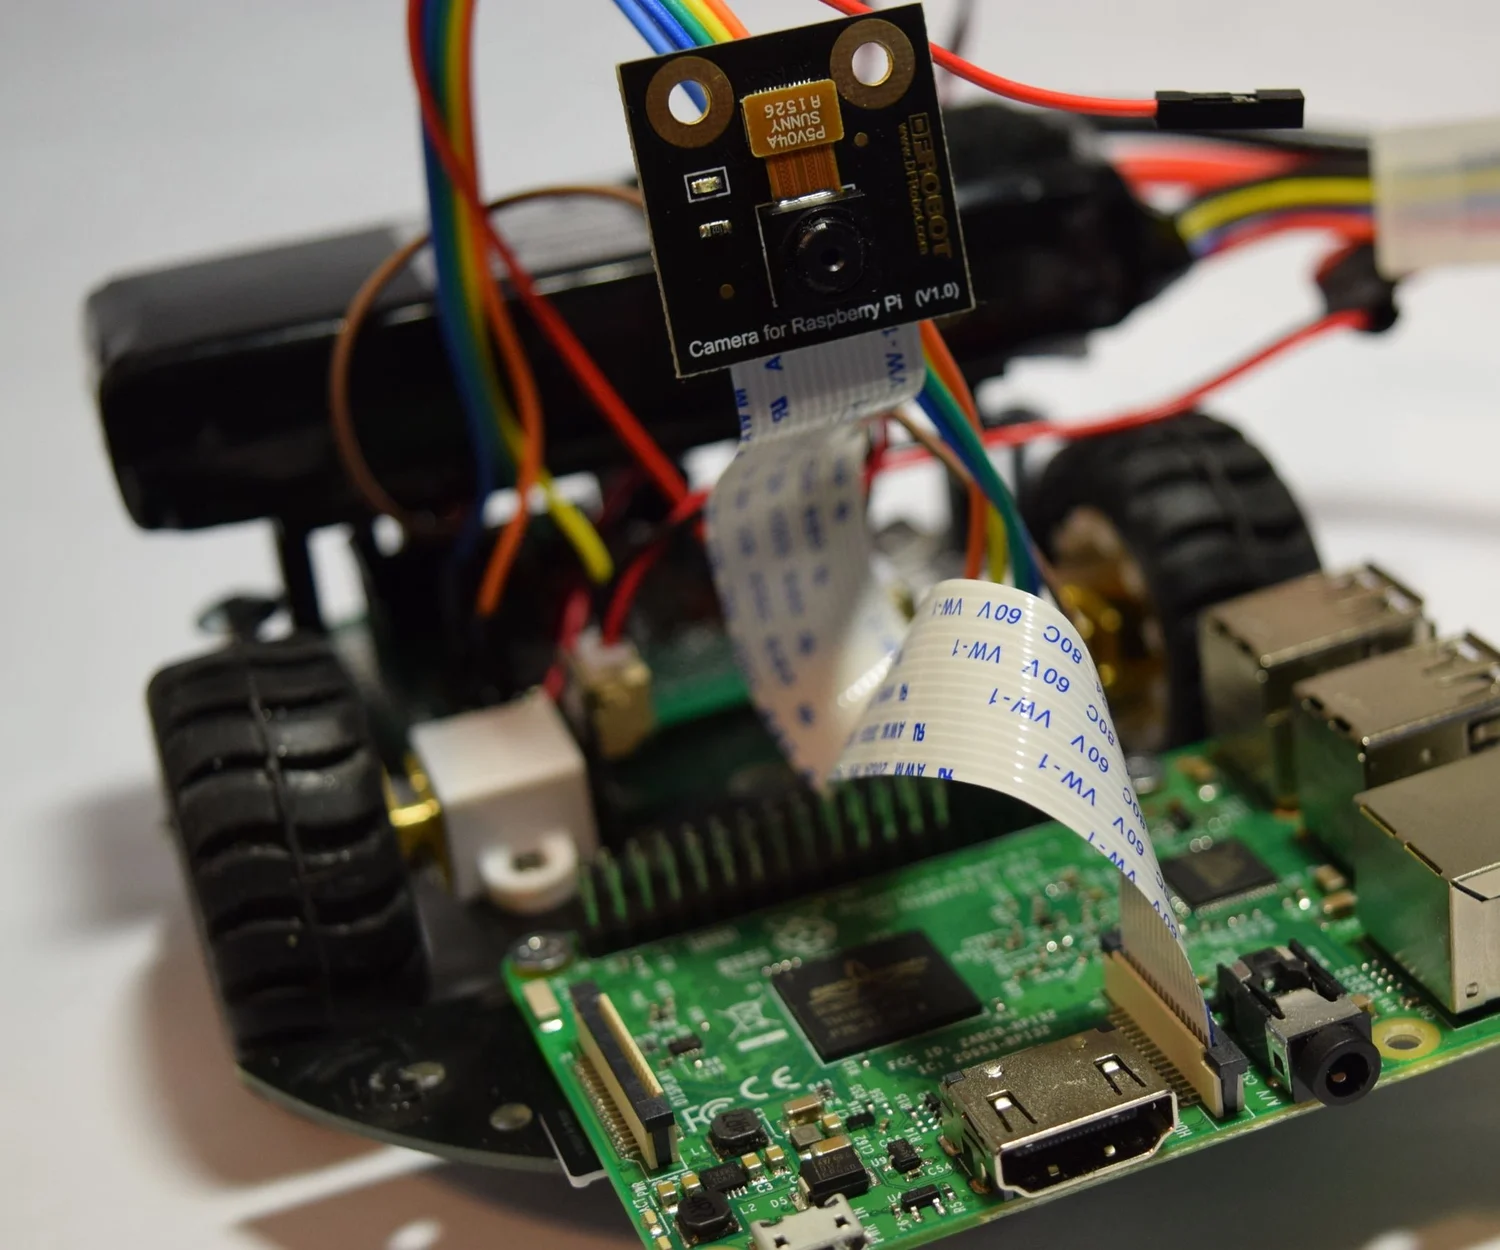
Embedded control.
A Raspberry Pi and control board operate the mobile platform through ROS.
02 / Mechanism studies
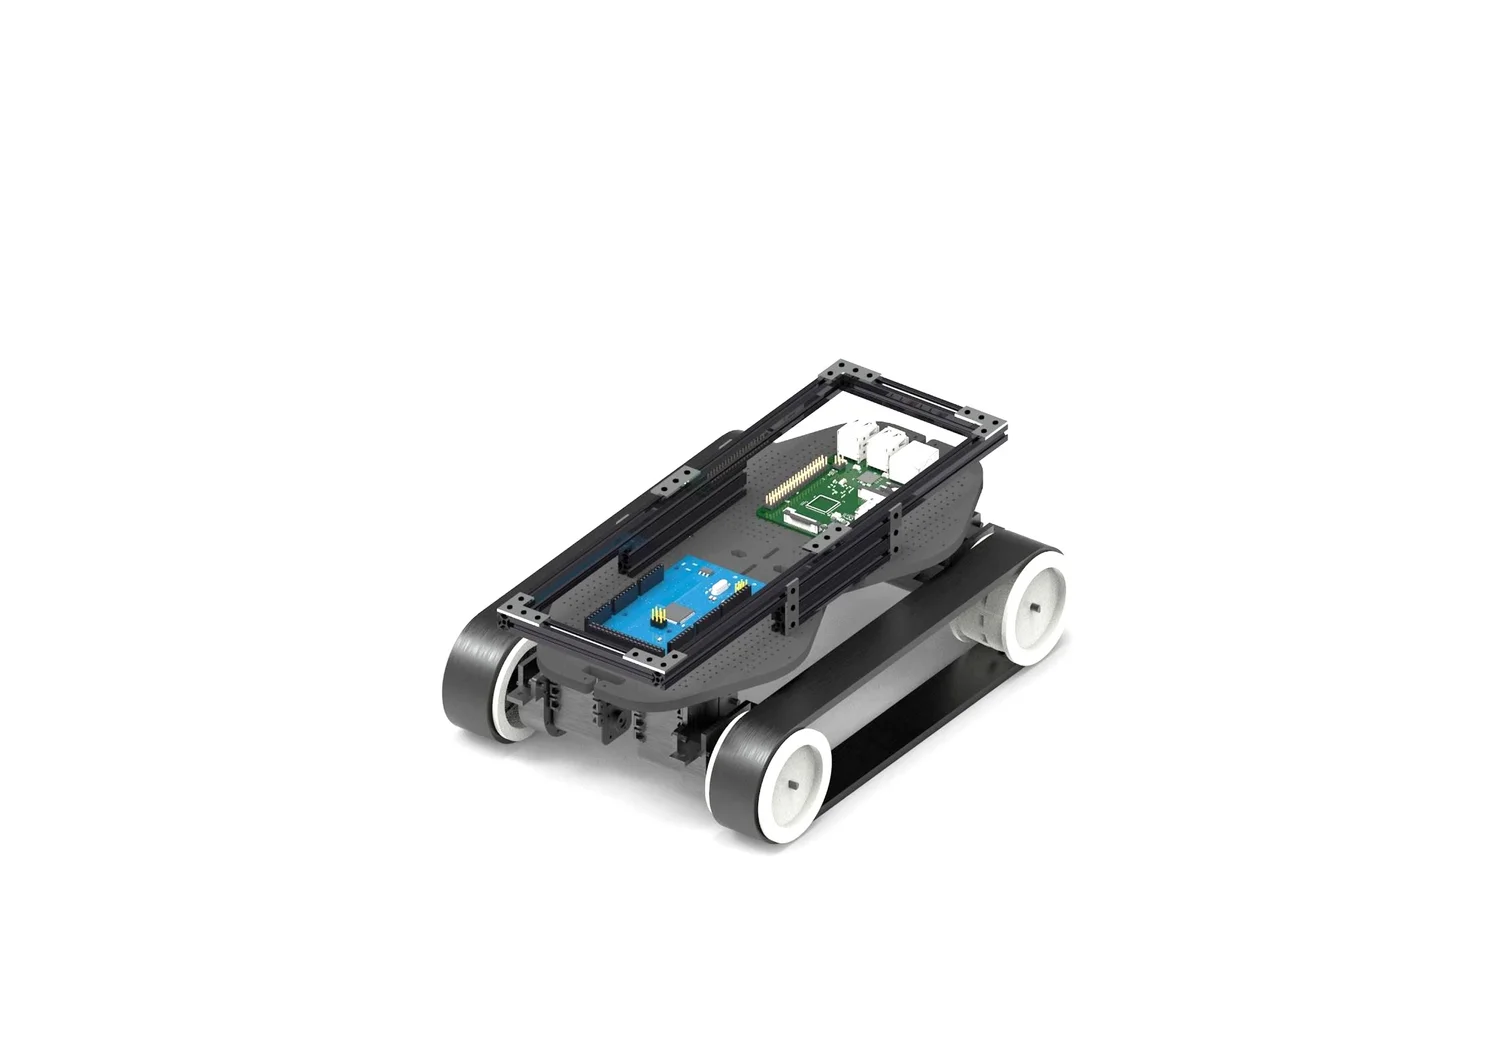
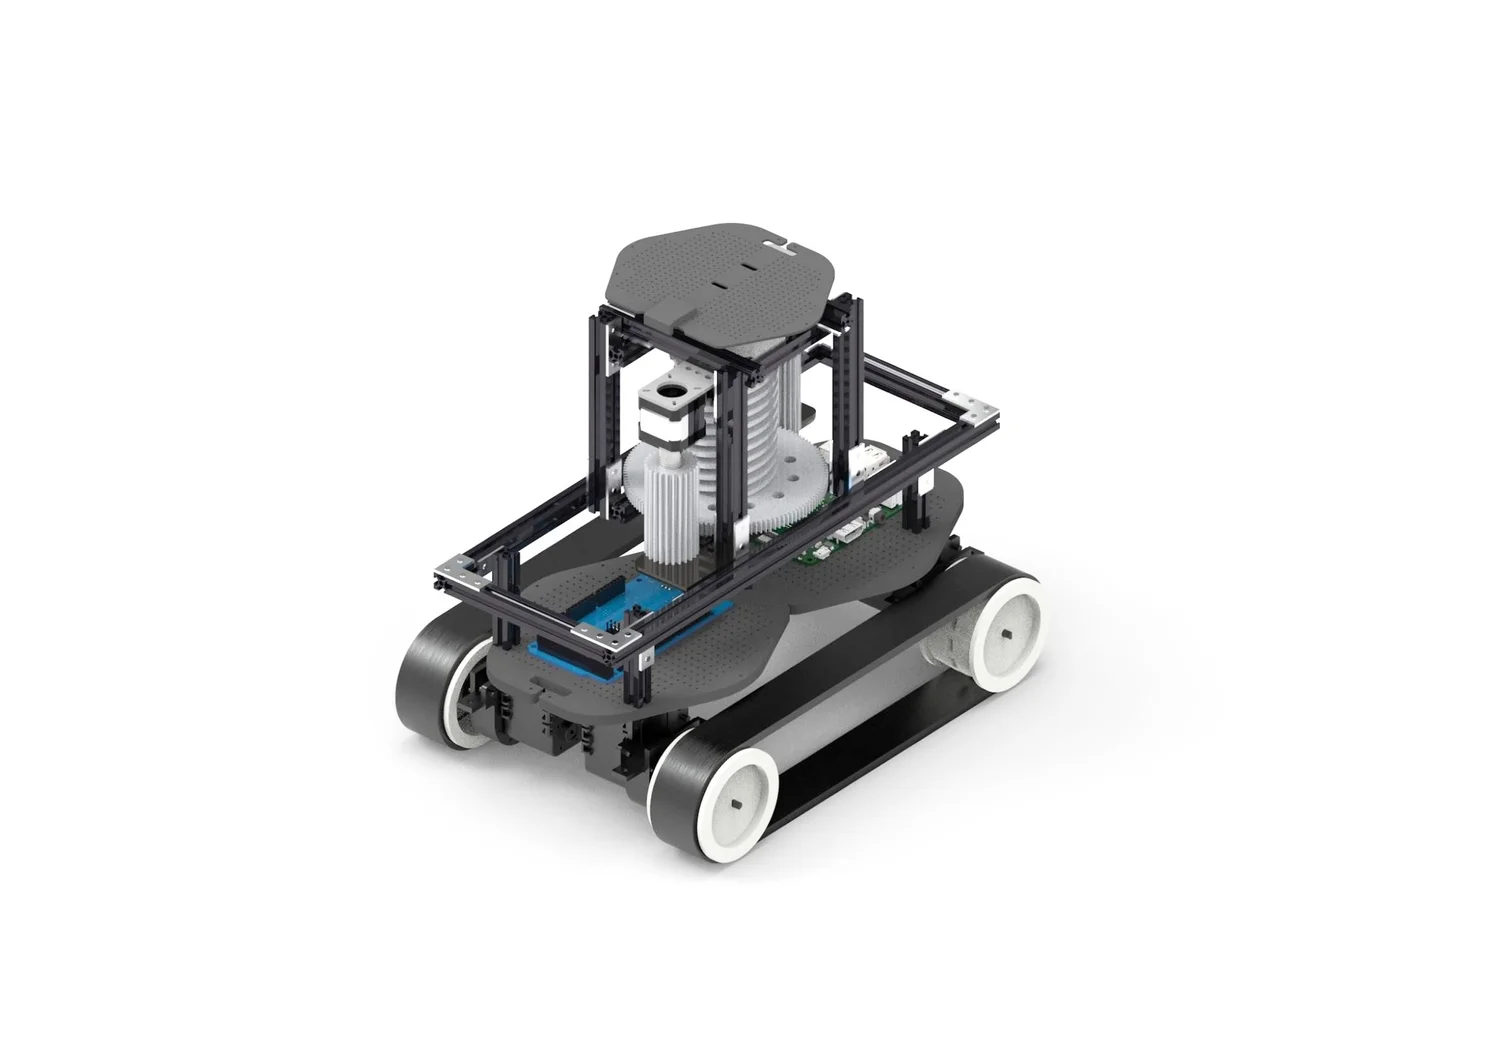
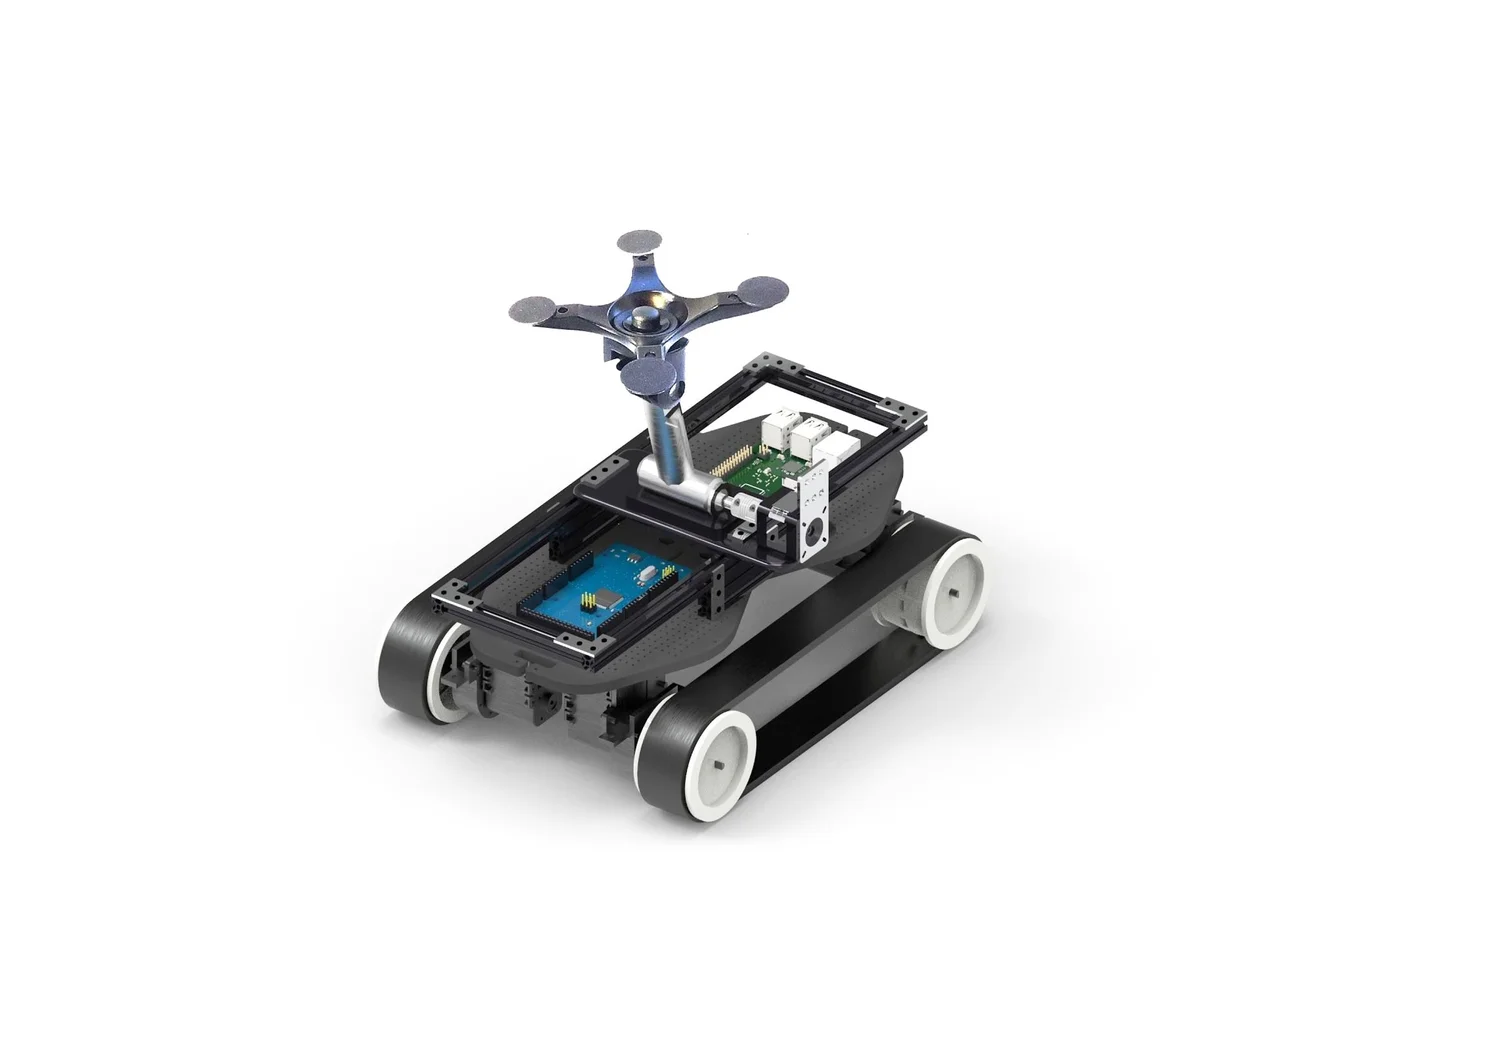
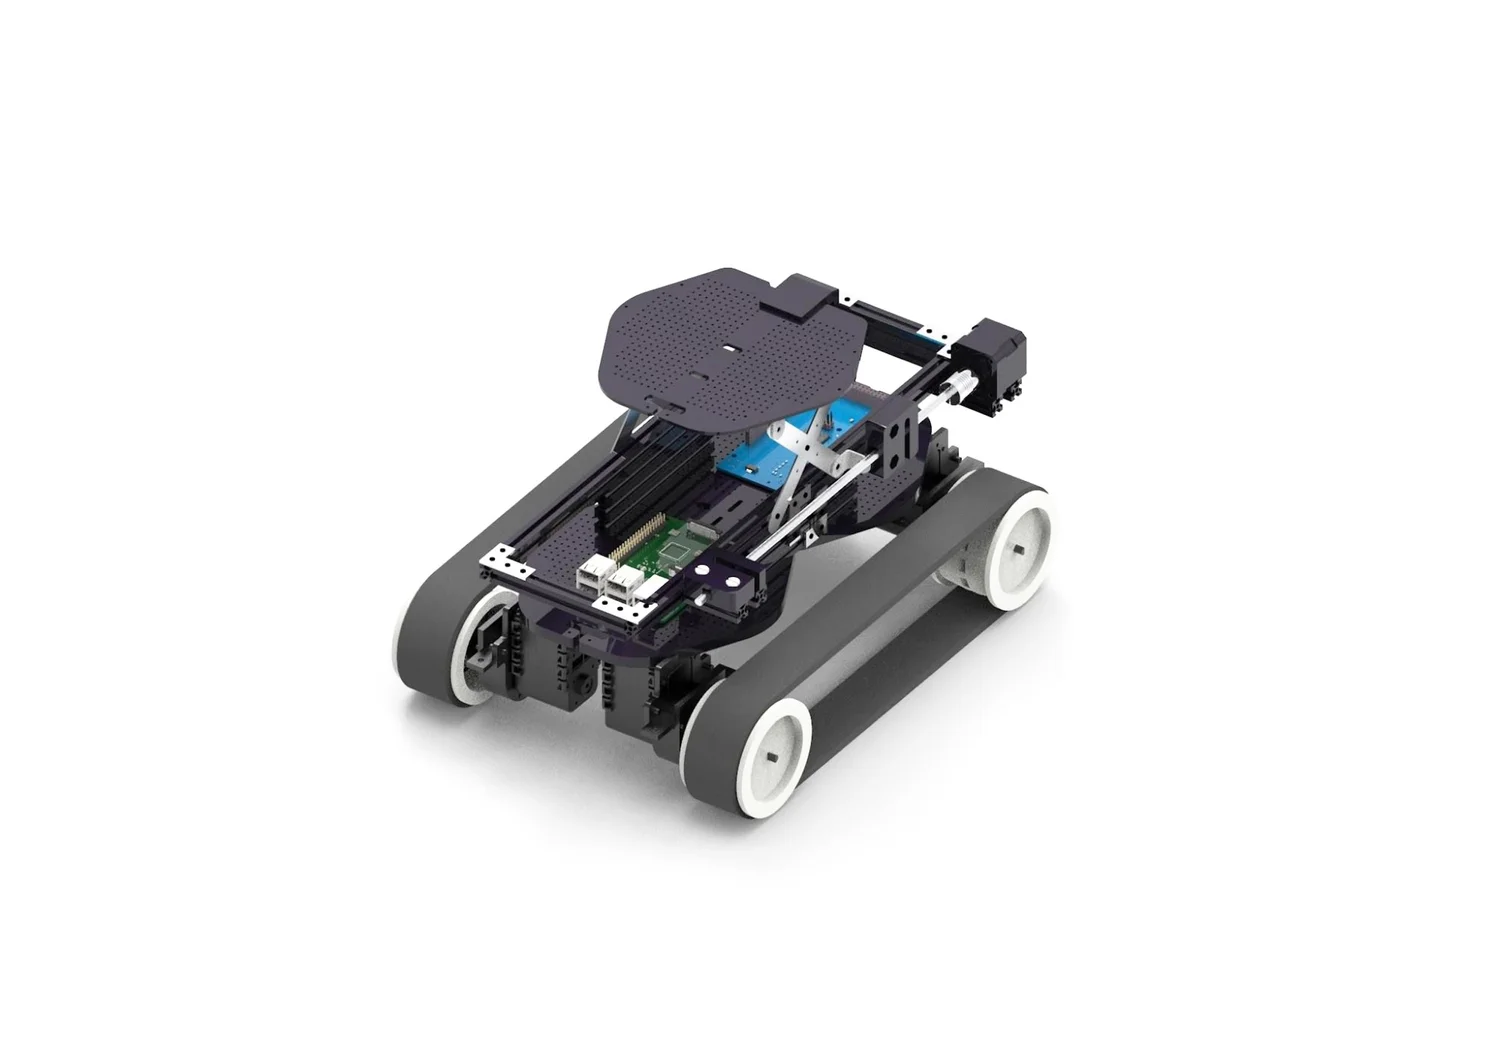
Four iterations.
One selected system.
Digital studies compare alternative lifting mechanisms before the selected design is developed as a physical prototype.
03 / Physical prototype
Scissor lift.
Three positions.
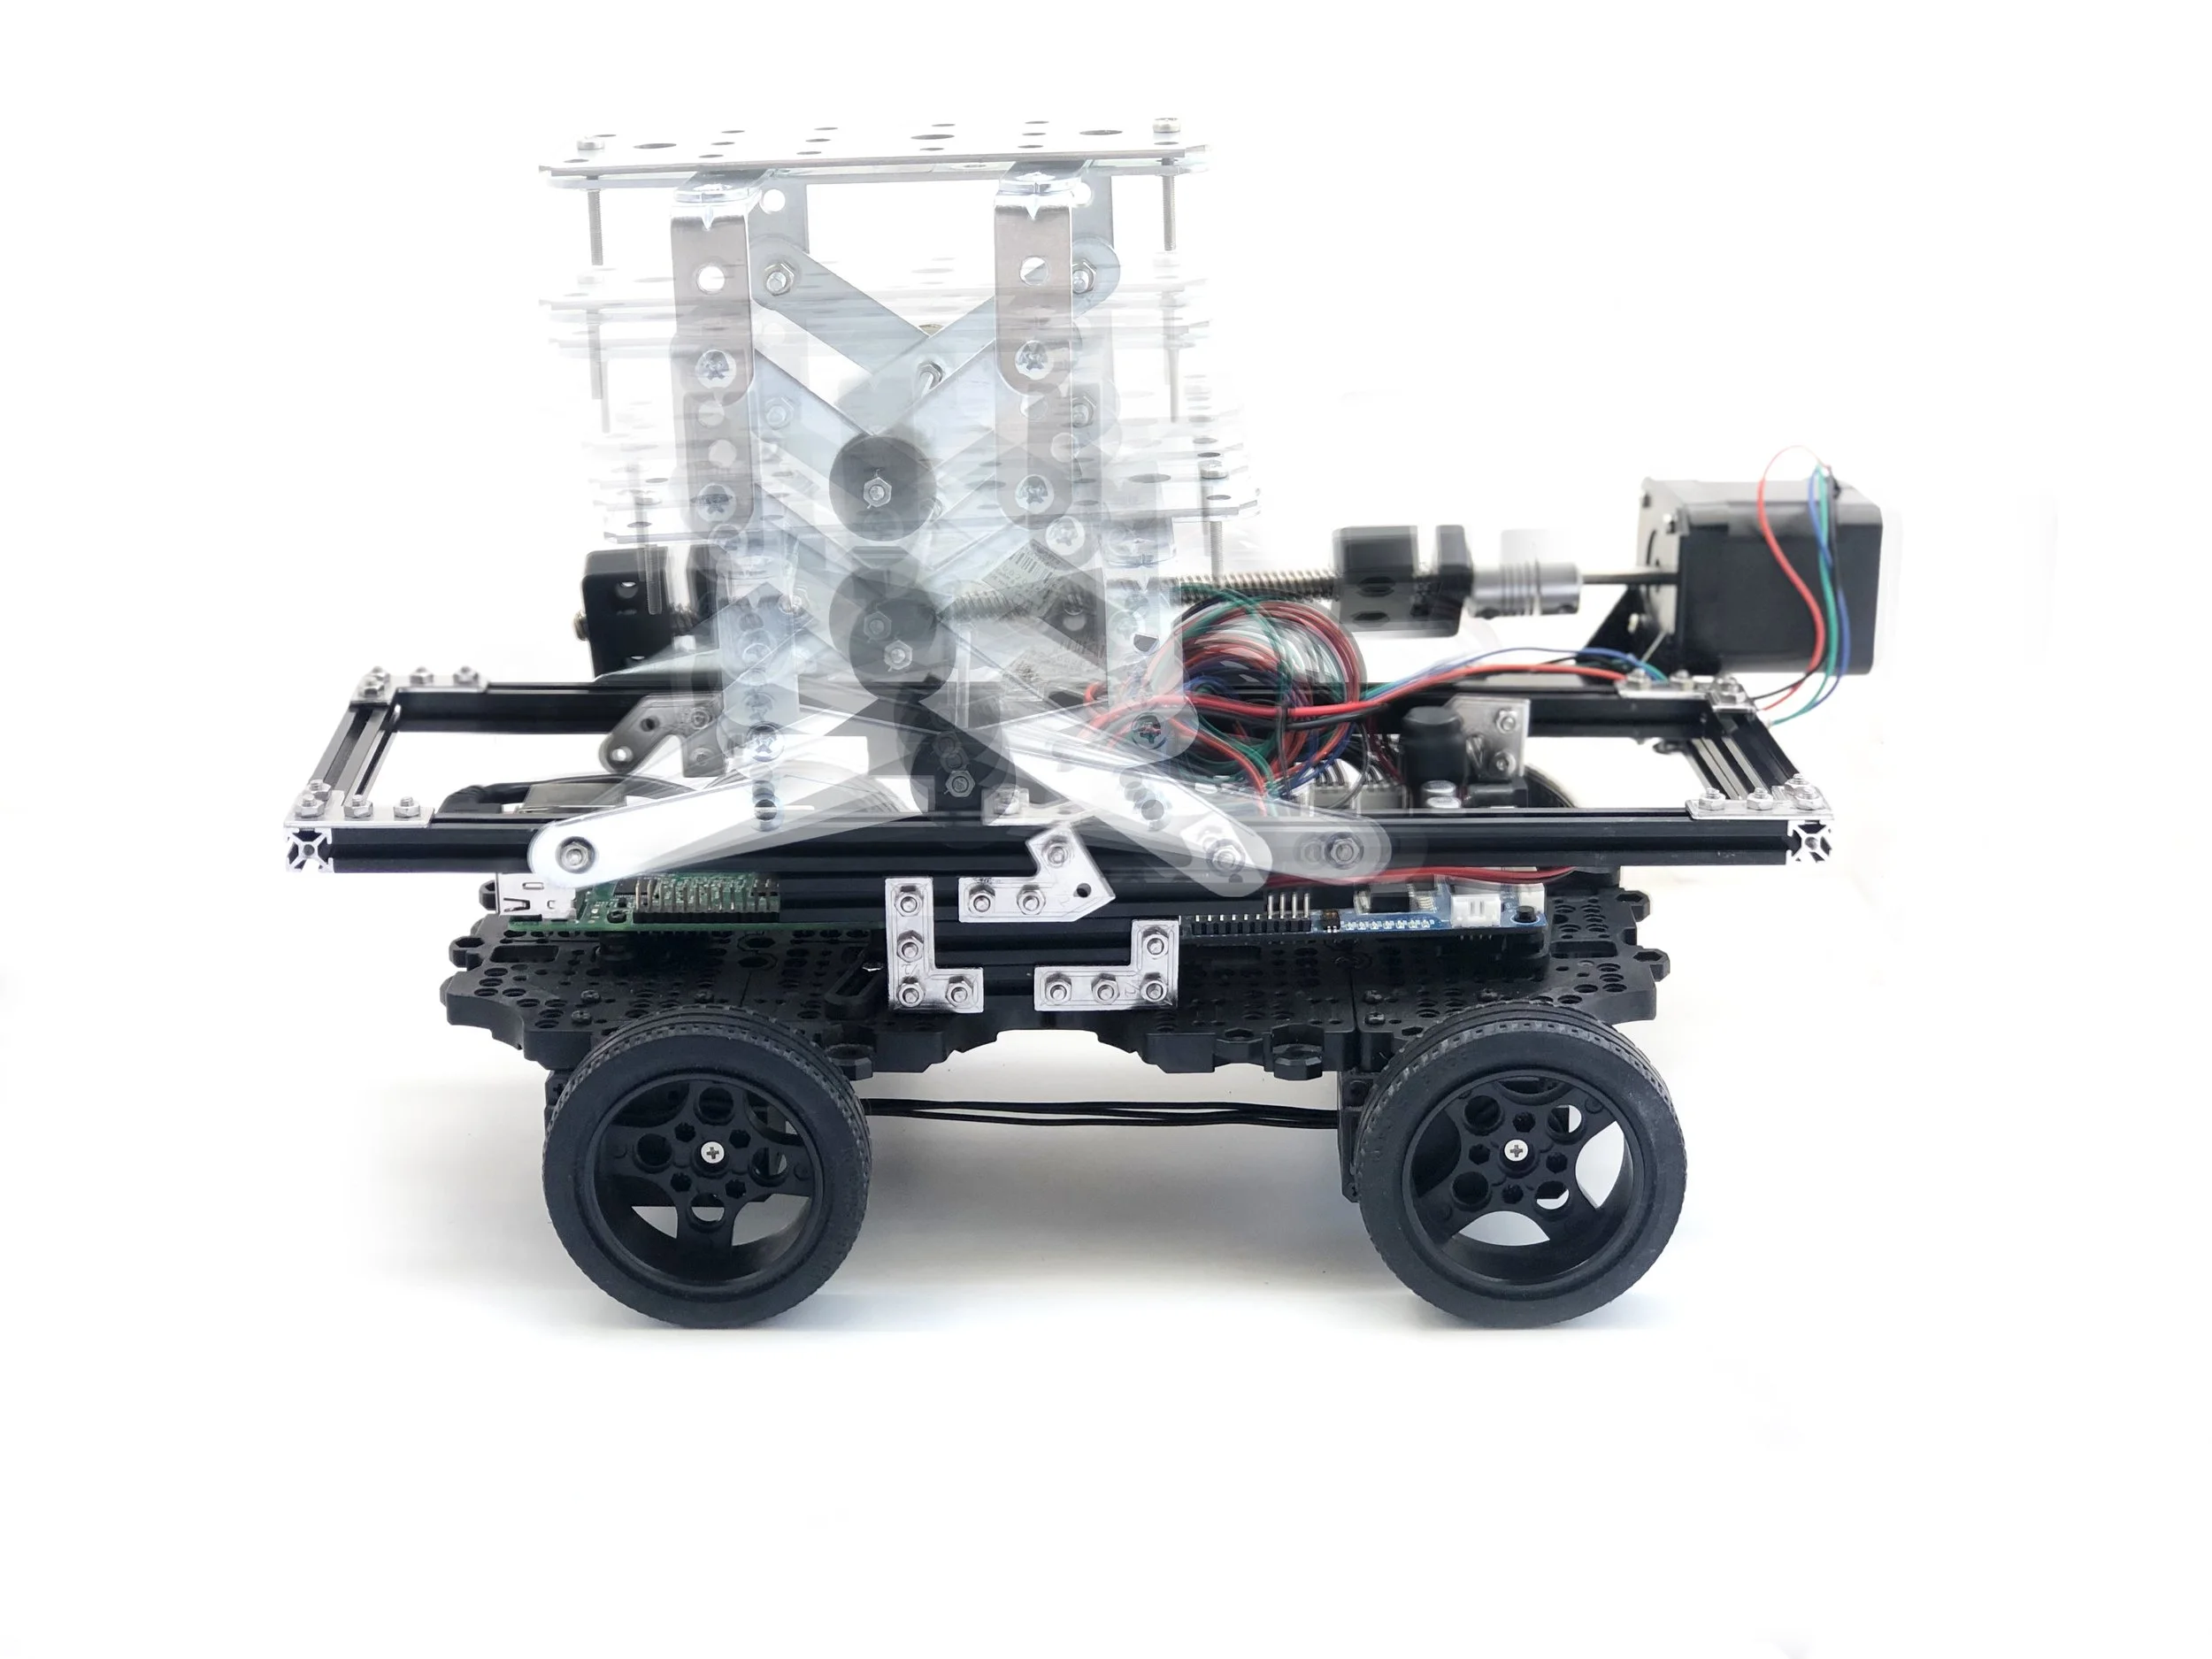
The physical assembly combines the mobile chassis with a scissor lifting platform, shown in lowered, intermediate and raised positions.
Research focus
Exploring how mobile robots could move and lift elements within adaptable urban environments.